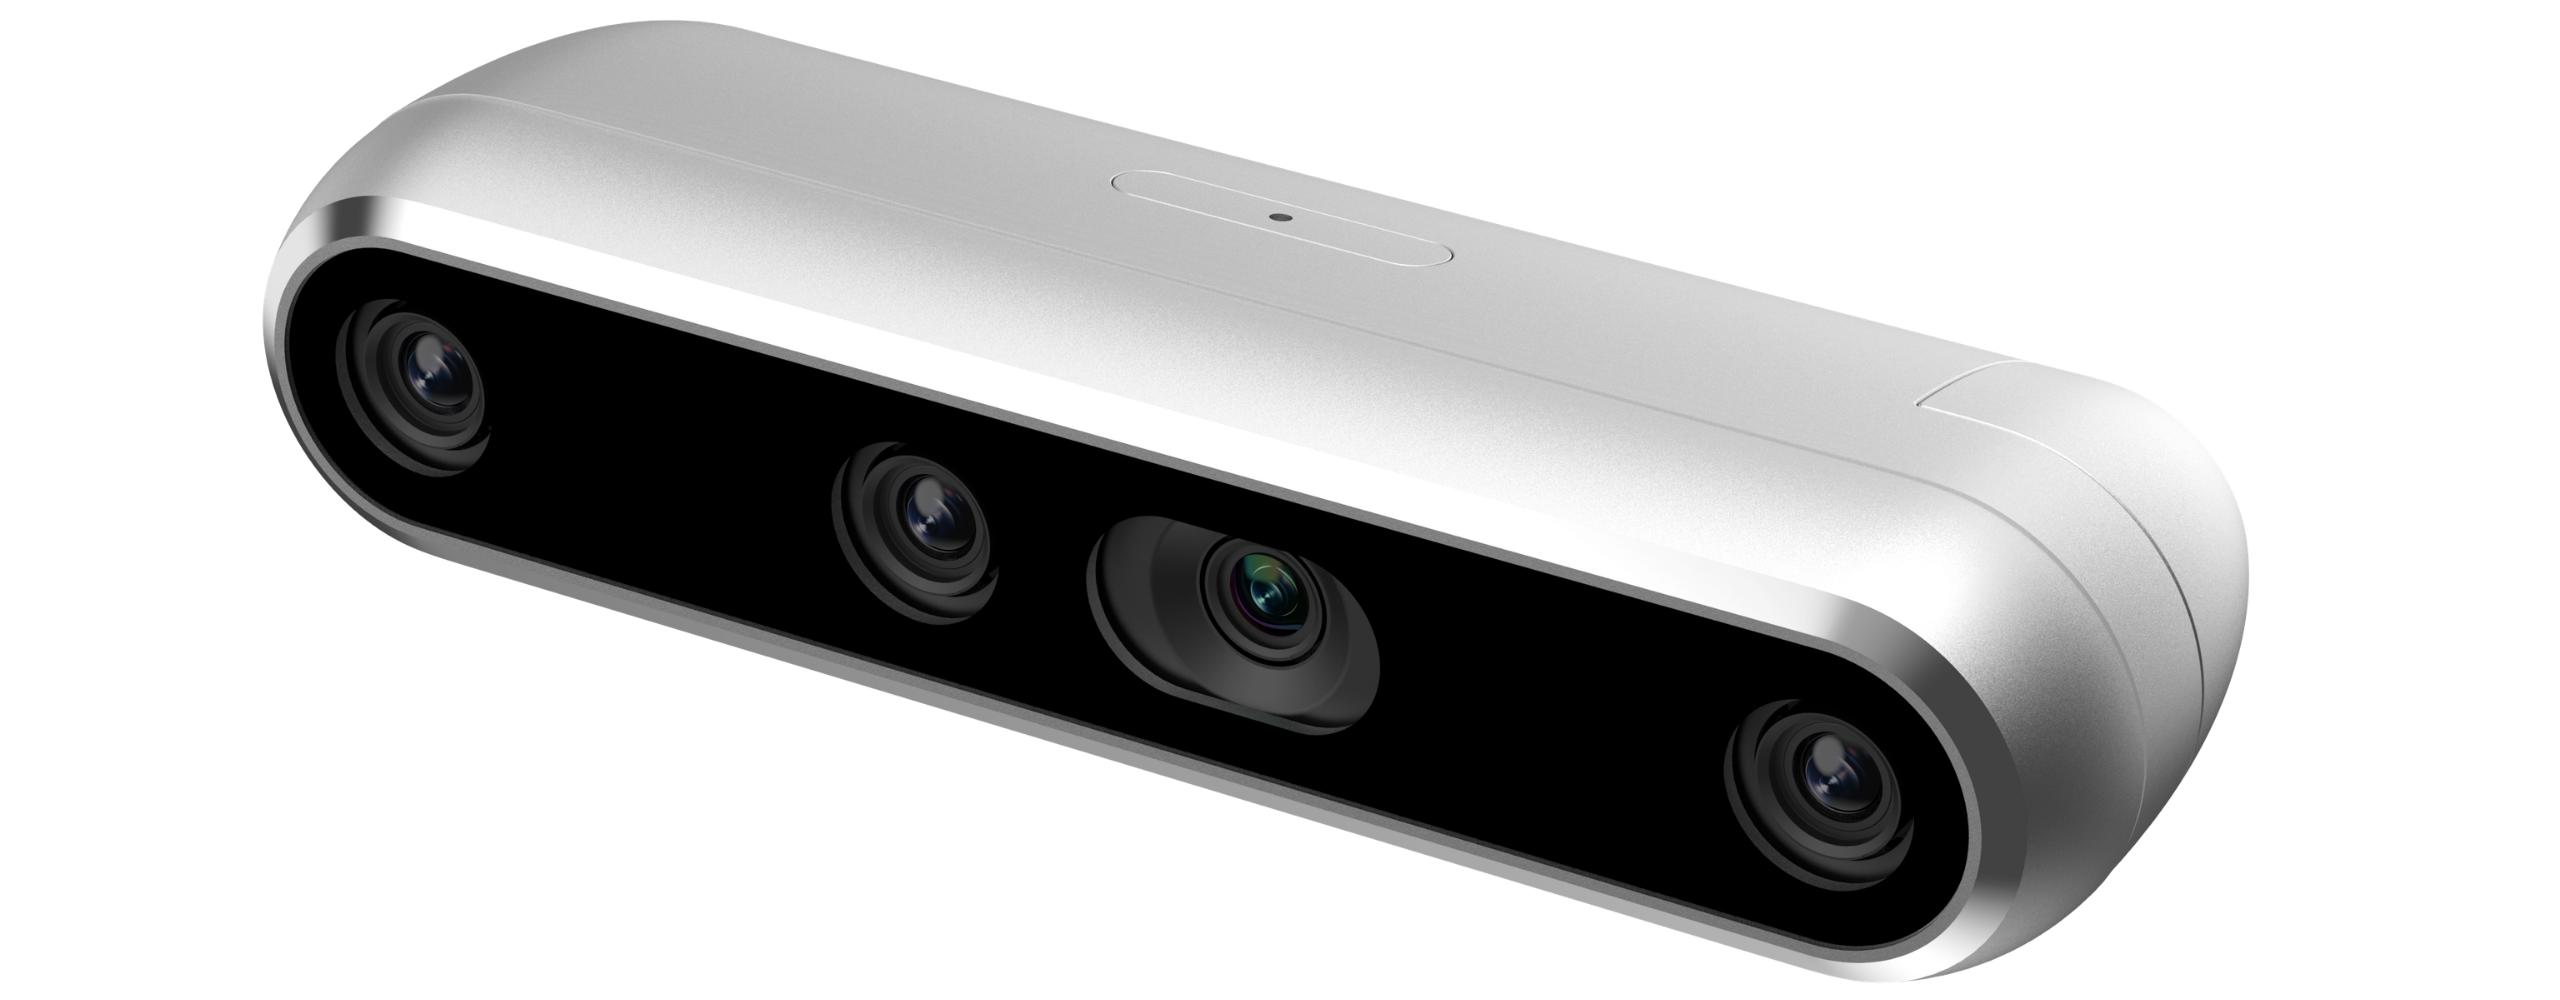

FOV 87° × 58°

Global Shutter

Ideal Range ~0.07 m to 6 m
The RealSense™ GMSL Depth Camera Portfolio delivers high-performance 3D vision for industrial robotics—enabling long-range, synchronized, low-latency perception across multi-camera systems.
HARDWARE
One architecture. Full perception.
Purpose-built for every layer of robotic and industrial perception.
D401 GMSL
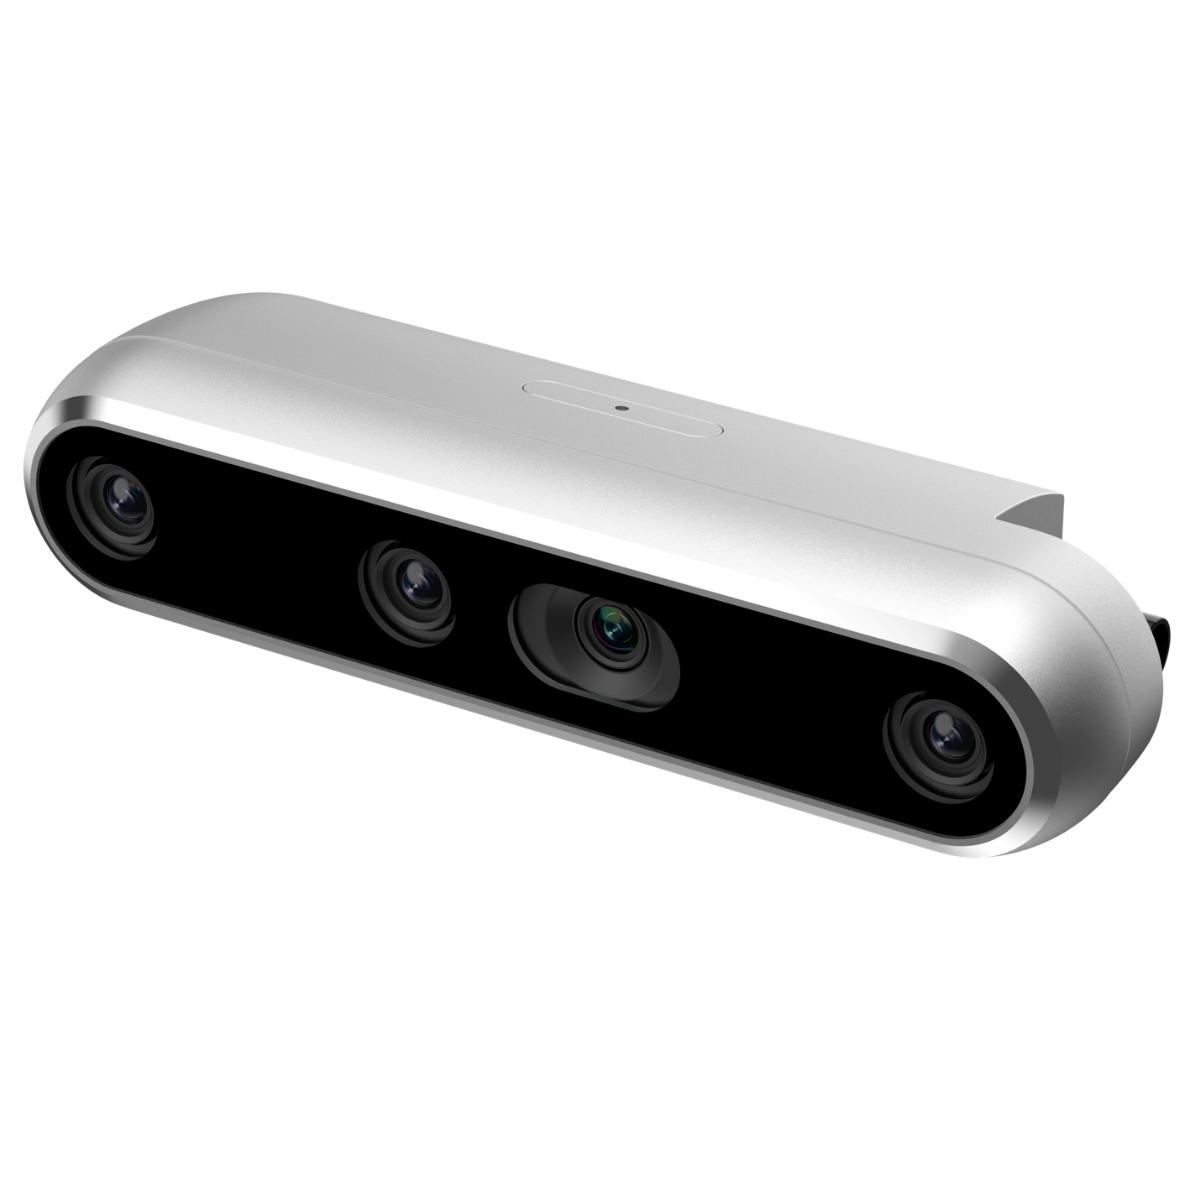
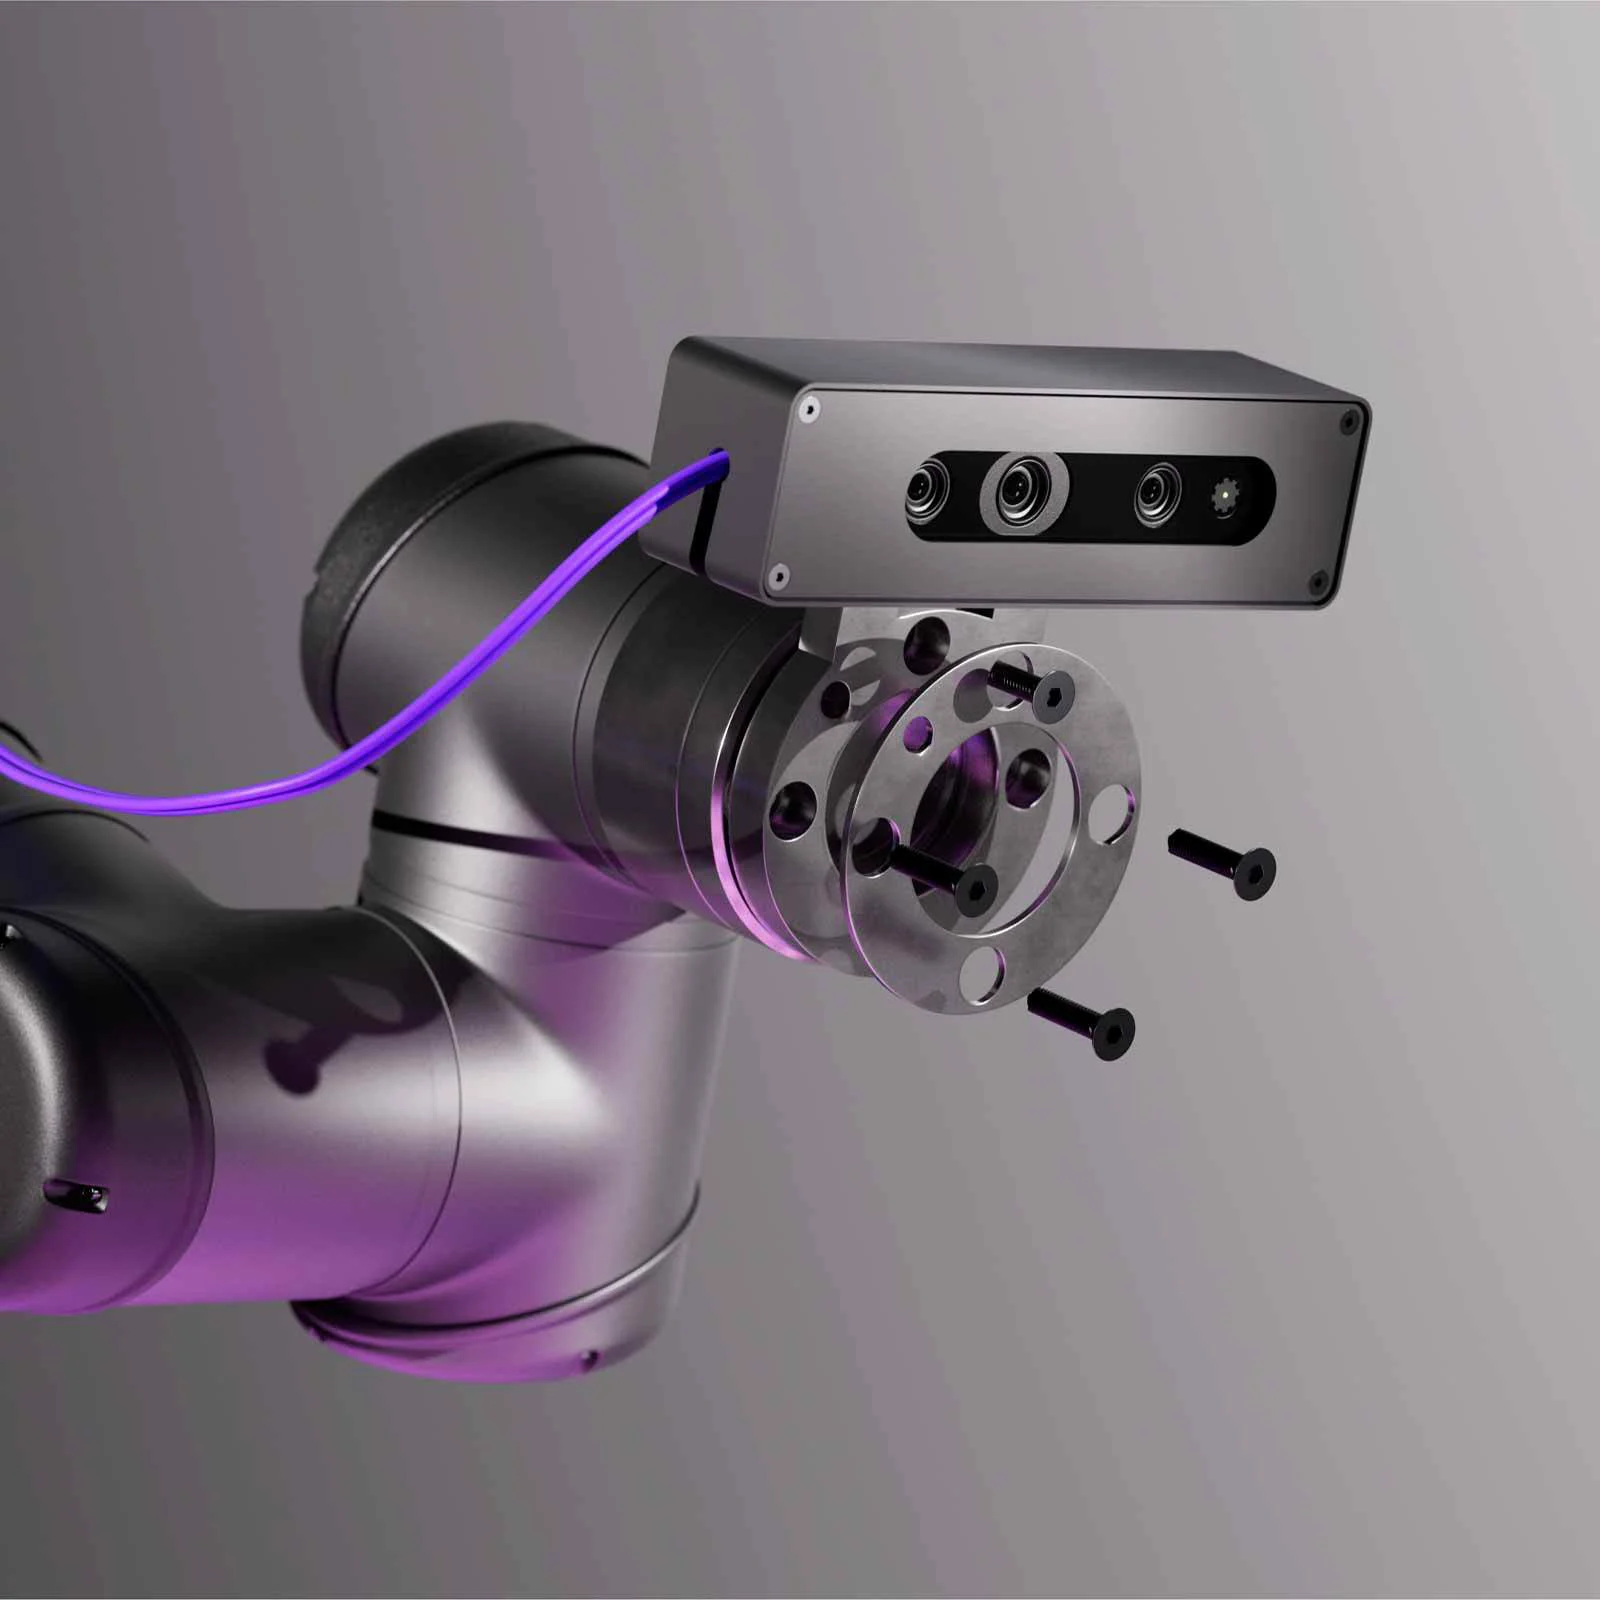
Precision Manipulation. High-accuracy, close-range depth for robotic hands, end-effectors, and inspection
D415 GMSL
Precise Measurement. Accurate depth for industrial scanning and metrology
D430 GMSL
Spatial Awareness. Wide FOV, mid-range depth for SLAM, navigation, and dynamic environments
D457 GMSL
Mobility Backbone. Long-range, ruggedized depth with IP-rated enclosure for AMRs and autonomous systems
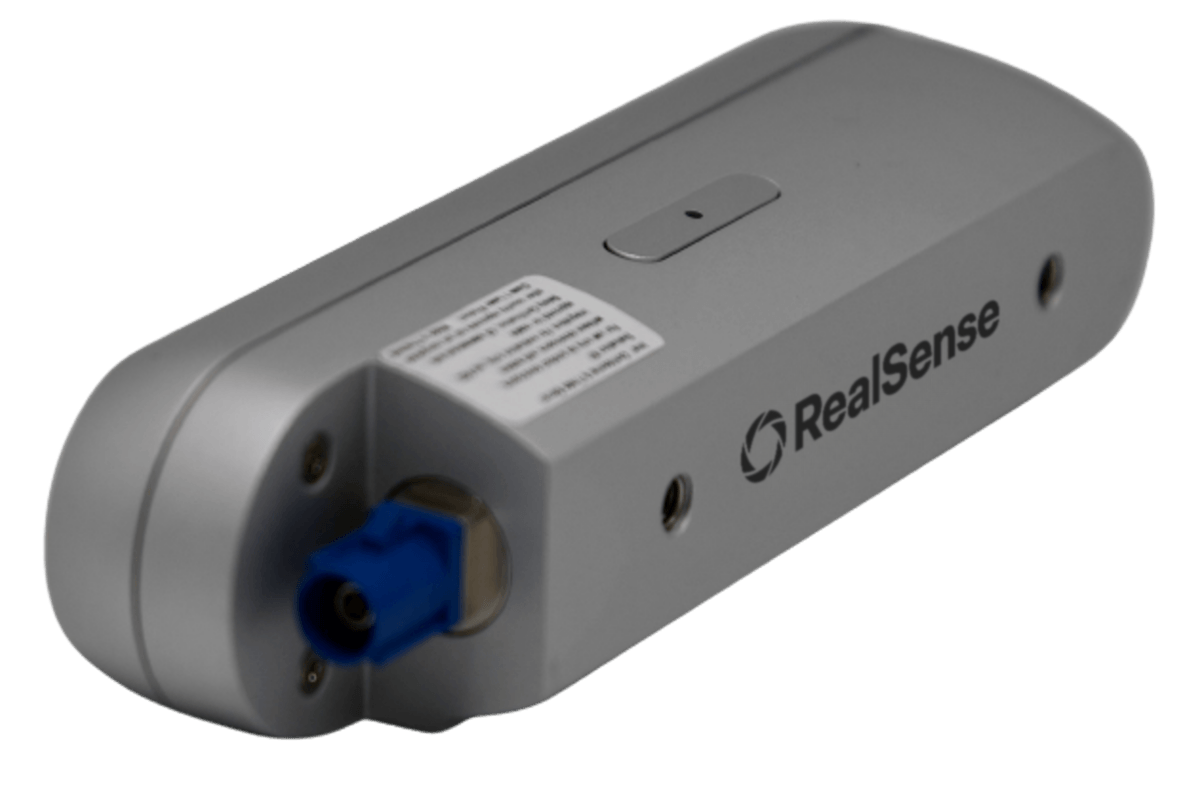
What is GMSL/FAKRA?
Gigabit Multimedia Serial Link (GMSL) is a multigigabit, point-to-point interface originally developed for automotive systems. It enables high-speed, low-latency data transmission over a single coaxial cable—supporting cable lengths up to 15 meters. Paired with secure, automotive-grade FAKRA connectors, GMSL brings reliable, high-performance connectivity to robotics and industrial environments.
Why GMSL/FAKRA?
GMSL/FAKRA enables synchronized, multi-camera perception—delivering stable, scalable, and deterministic 3D vision for autonomous systems.
- Longer cable reach (up to 15m)
- Lower latency for real-time perception
- Reduced EMI/ESD sensitivity
- Lower power consumption
- Higher bandwidth with multi-stream support
Industrial-grade connectivityfor scalable perception
Built on GMSL/FAKRA, the RealSense GMSL portfolio enables synchronized, multi-camera perception systems designed for real-world deployment.
Long cable runs, deterministic timing, and simplified system architecture allow multiple cameras to operate as a single, coordinated system.
Combined with secure connections and reduced EMI/ESD sensitivity, this architecture ensures stable performance in electrically noisy, high-vibration industrial settings.
With up to 4 cameras per interface, and scaling 8+ cameras per system, GMSL enables full-system perception rather than single-sensor deployments.
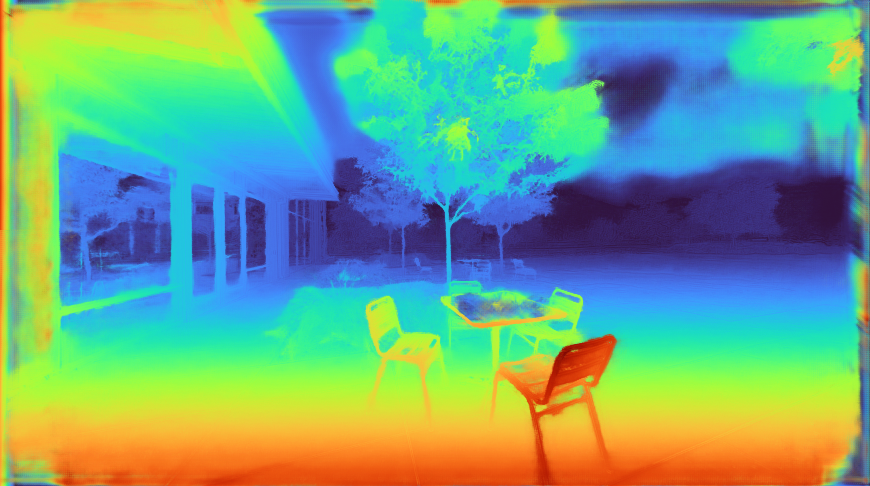
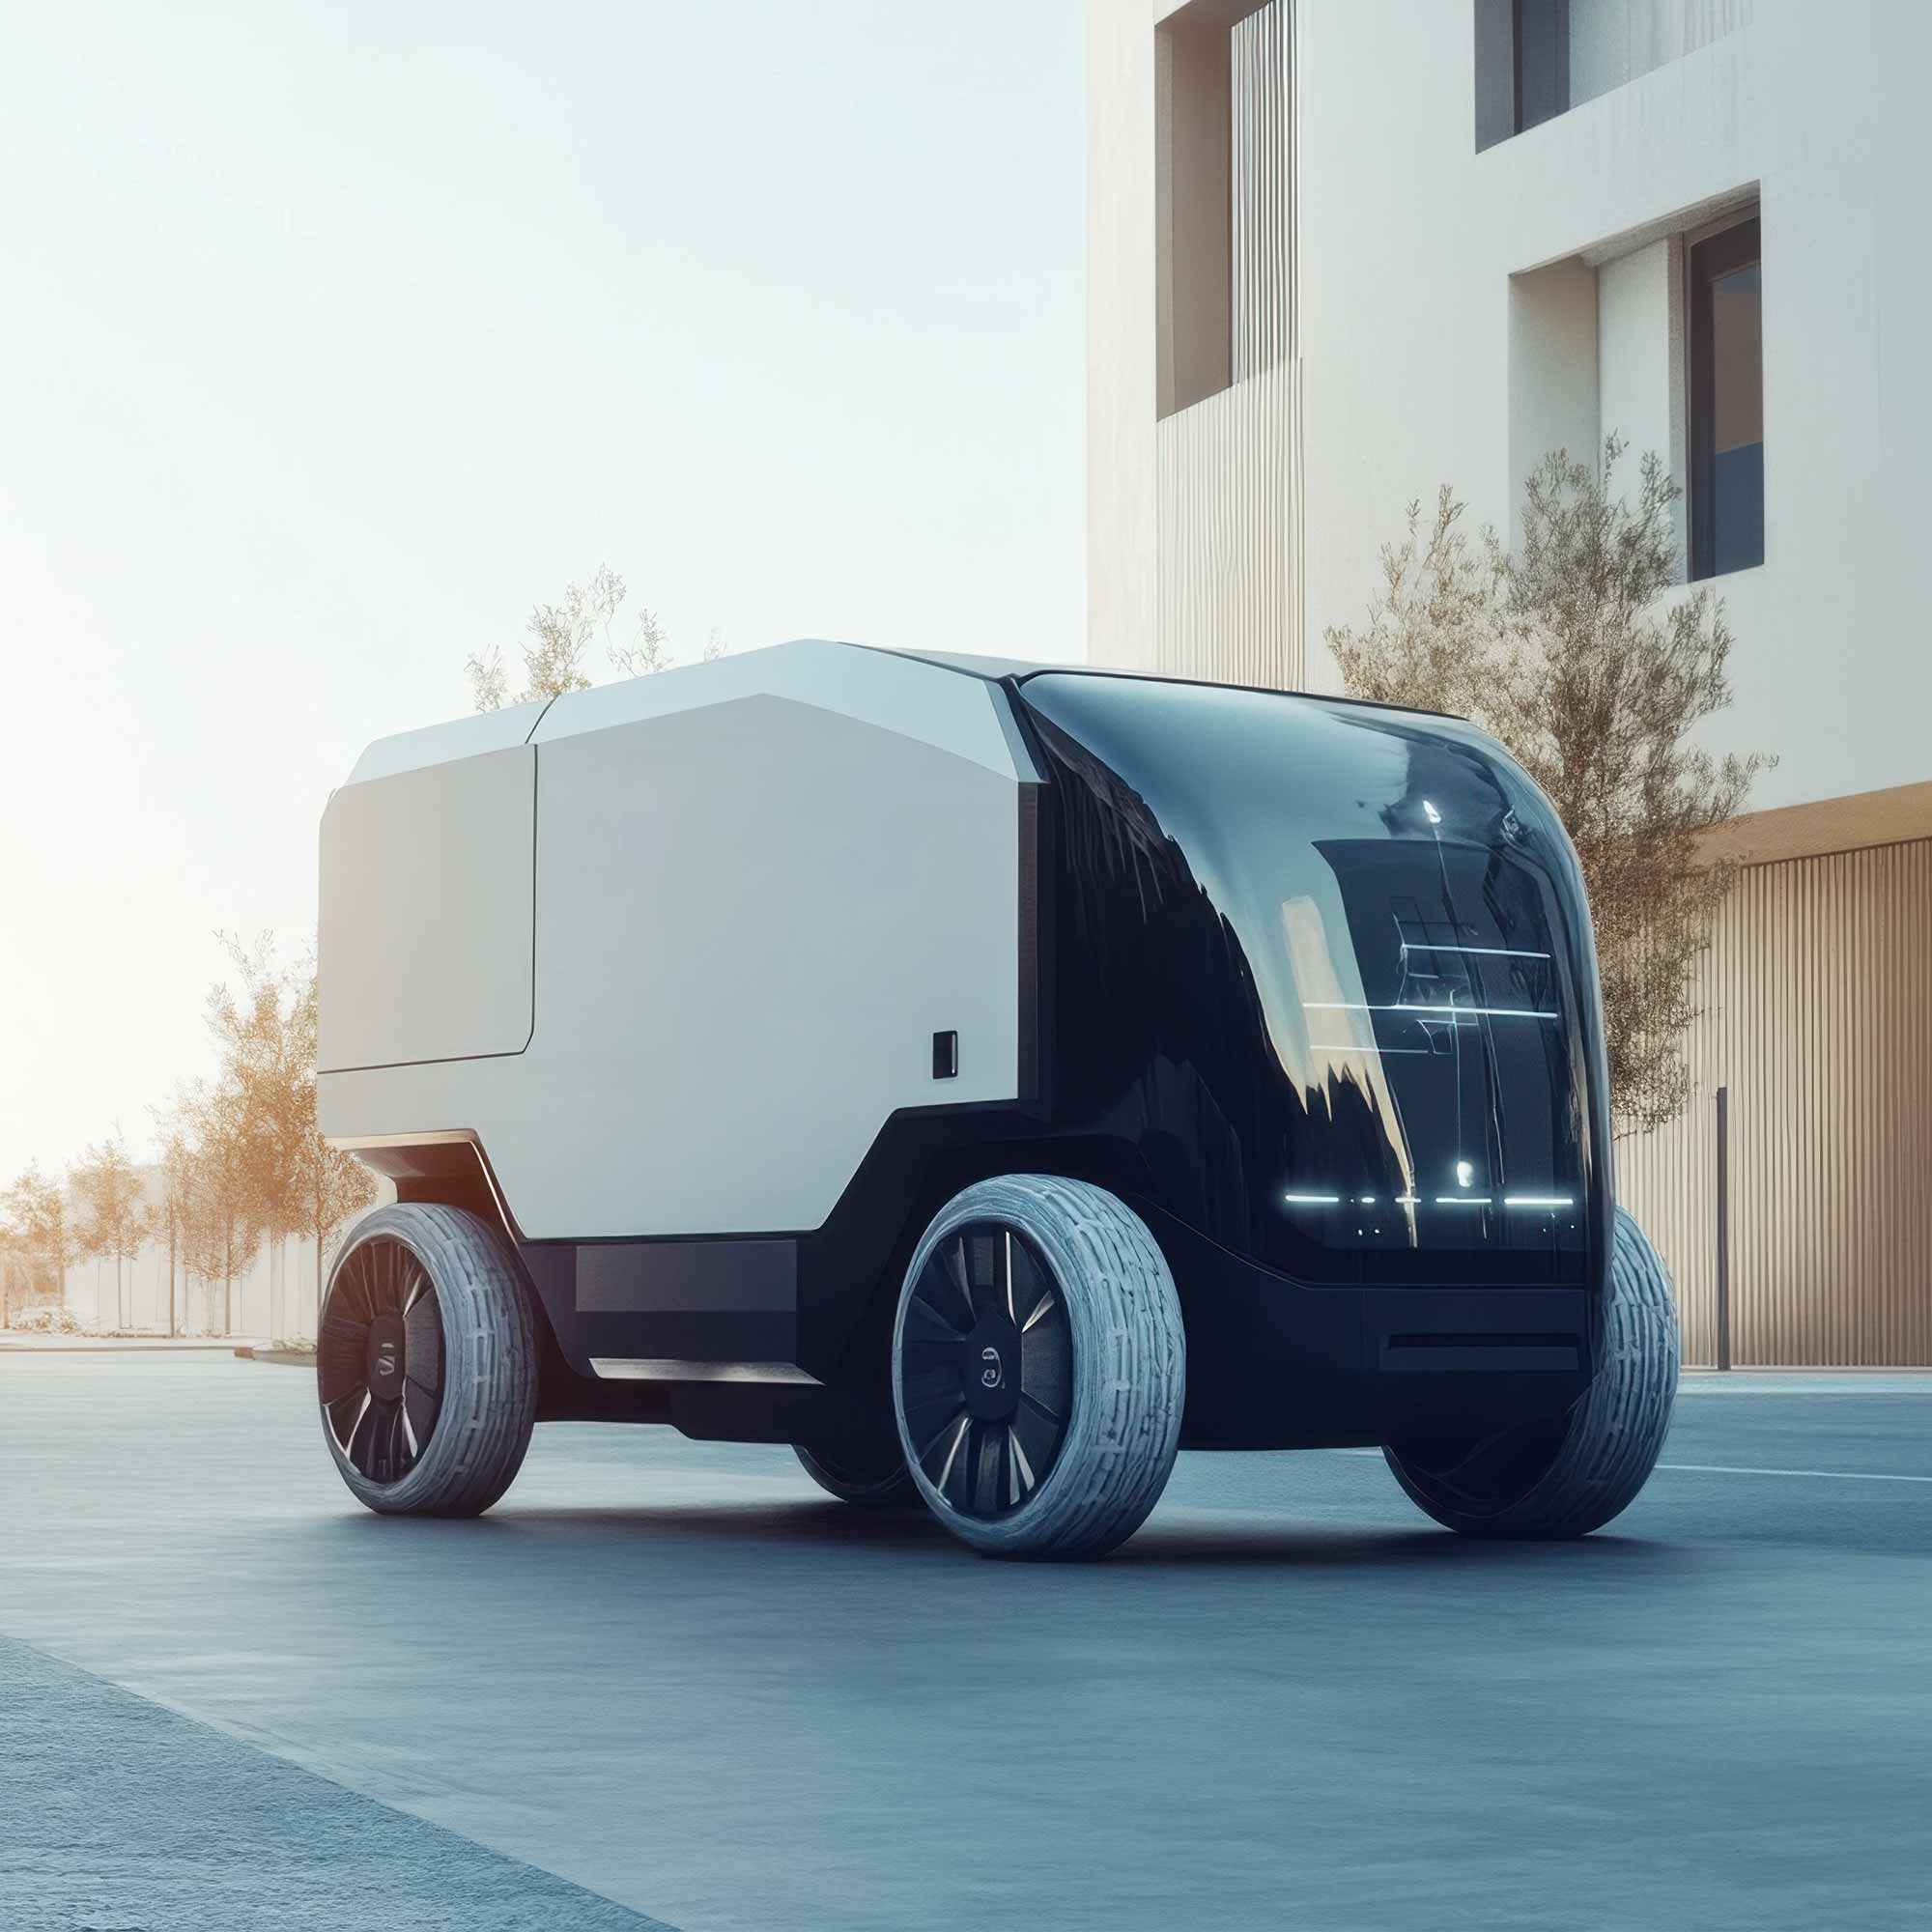
Best for Autonomous Mobile Robots
Adding an automotive-grade FAKRA connector, a GMSL high-speed serializer, and an IP65 grade enclosure makes it the best fit for autonomous mobile robots (AMR), automotive infotainment, and driver monitoring. The D457 is supported by the same cross-platform, open-source RealSense™ SDK 2.0, and requires a separate kernel driver package for the GMSL serializer. The kernel driver is open-source and can be easily integrated into various platforms.
Reliable perception in real-world environments
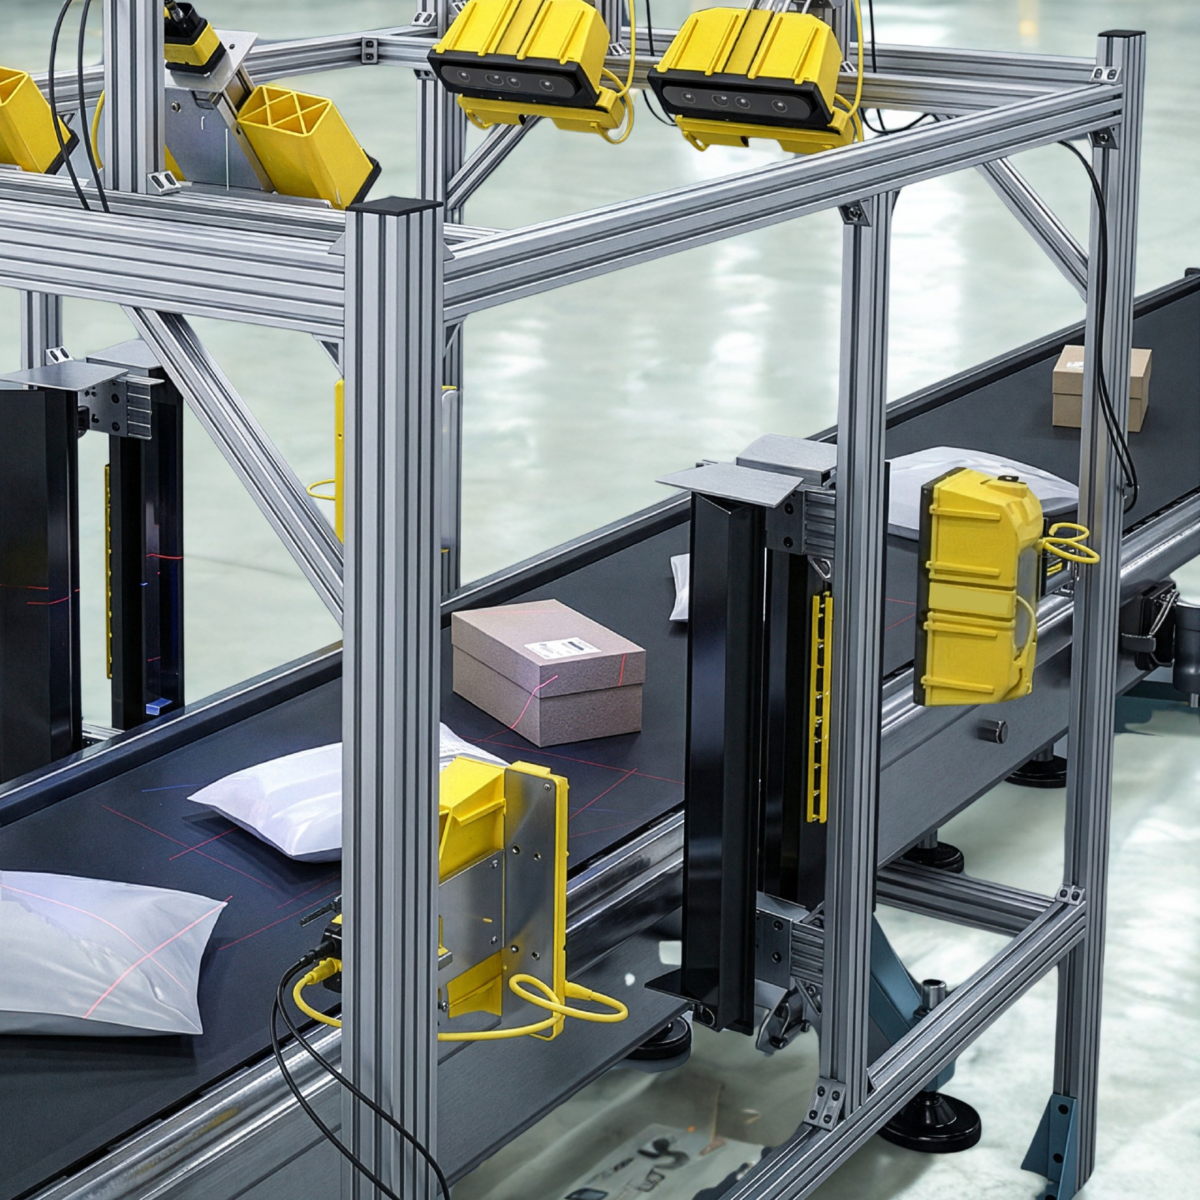
Industrial robots fail when perception is inconsistent. The GMSL architecture delivers:
- Stable depth under motion
- Reduced electrical noise interference
- Long cable runs without signal degradation
- Deterministic synchronization across sensors
This enables predictable performance in warehouses, factories, and outdoor environments.
Designed for vision-based AI applications
RealSense stereo depth enables machines to see in 3D, accelerating AI deployment. Systems can:
- Navigate and avoid obstacles
- Perform object detection and tracking
- Execute precise pick-and-place tasks
- Enable SLAM and VIO for autonomous movement
This reduces training time and increases reliability across robotic applications.
Best for Industrial Robotics and Autonomy
The GMSL portfolio is optimized for:
- Autonomous Mobile Robots (AMRs)
- Humanoid robotics
- Industrial automation and cobots
- Warehouse logistics and bin picking
- Inspection and quality control
- Autonomous vehicles and outdoor scanning
These systems benefit from synchronized, scalable, and rugged perception designed for real-world deployment.
Tech Specs
Feature
D401
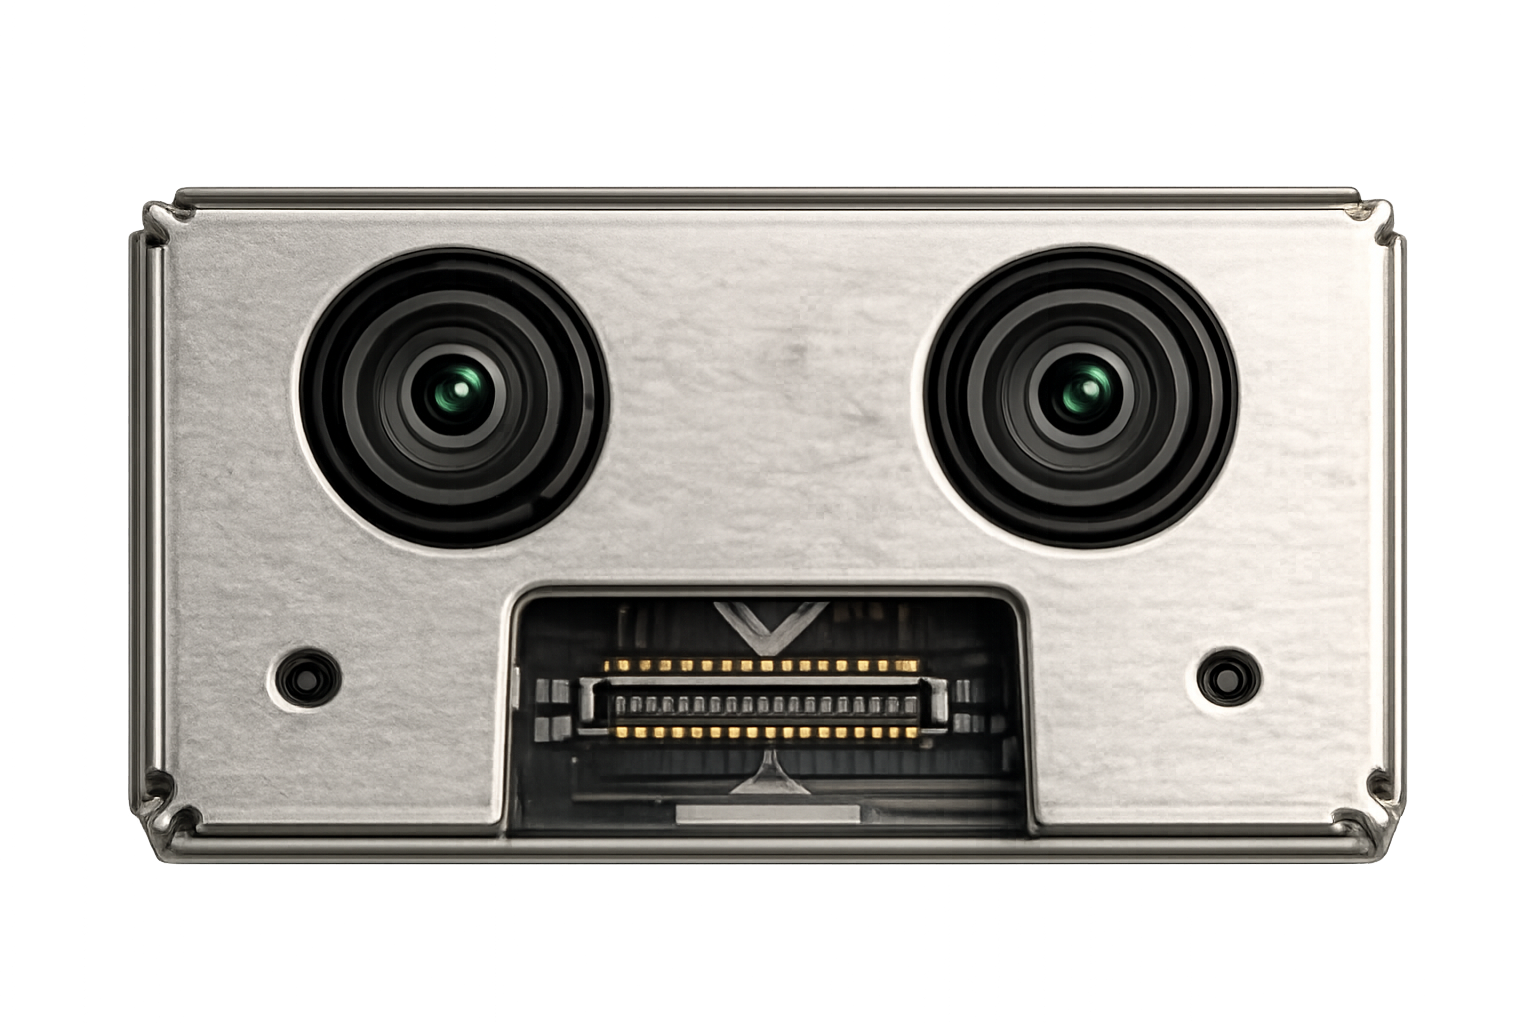
D415
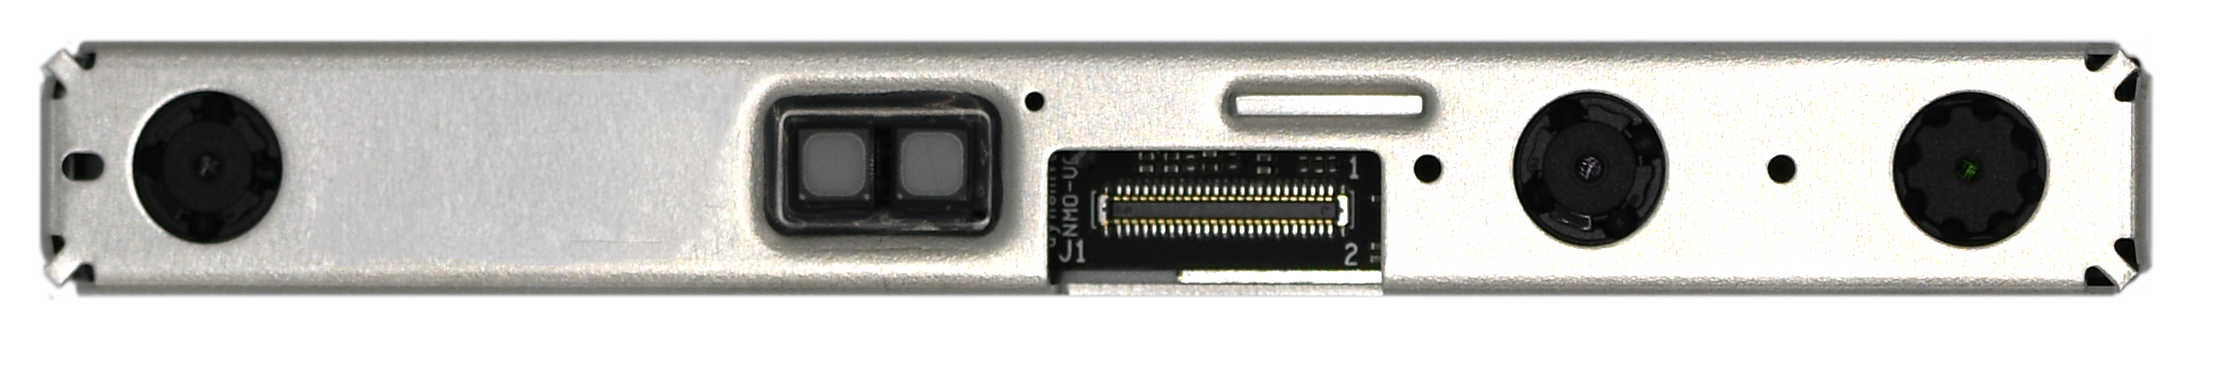
D430
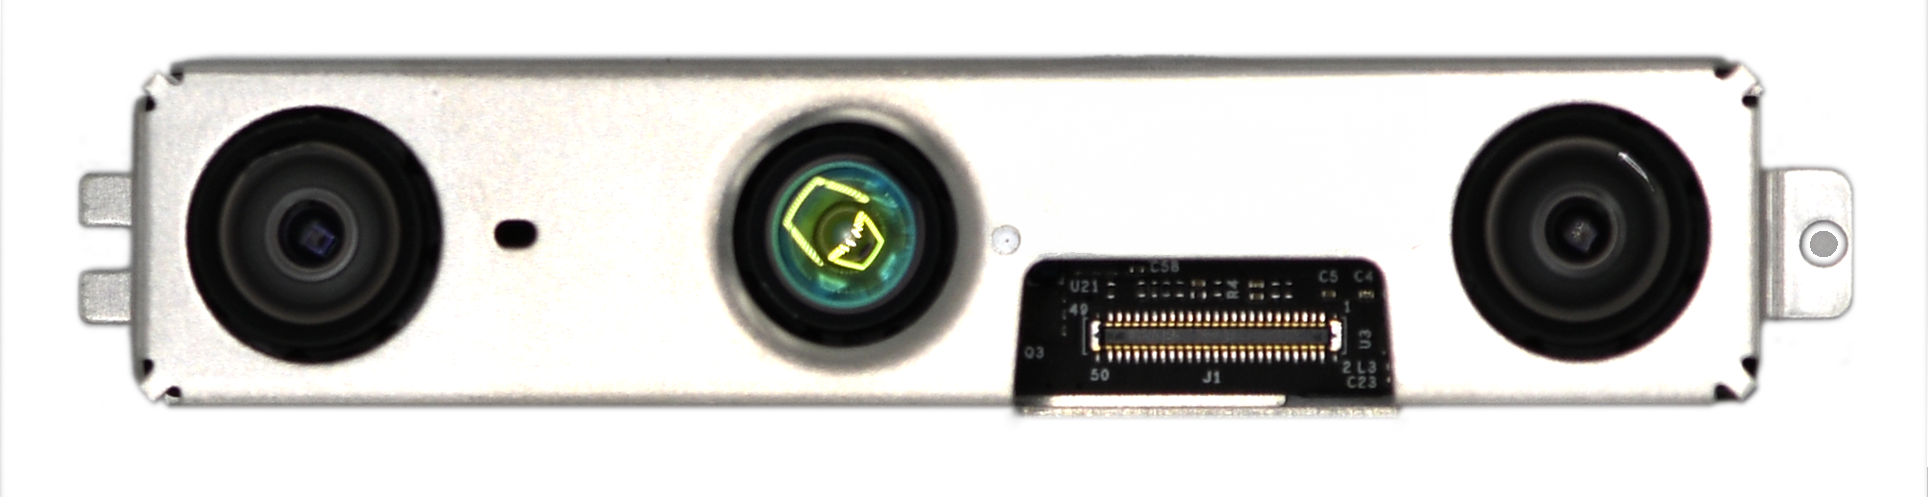
D457
Ideal Range
0.07–0.5 m
0.5–3 m
0.3–3 m
0.6–6 m
Depth FOV
84° × 58°
65° × 40°
87° × 58°
87° × 58°
Frame Rate
Up to 90 fps
Up to 90 fps
Up to 90 fps
Up to 90 fps
Interface
GMSL
GMSL
GMSL
GMSL / USB
Key Use
Manipulation
Measurement
Navigation
Mobility
All models supported by RealSense SDK 2.0
Leveraging the power of
SDK 2.0
Build the future with the open source RealSense™ SDK 2.0 and depth tools. Platform independent, the SDK supports all current RealSense depth cameras and includes wrappers for many common platforms and languages.
Proven in Real-World Physical AI
-
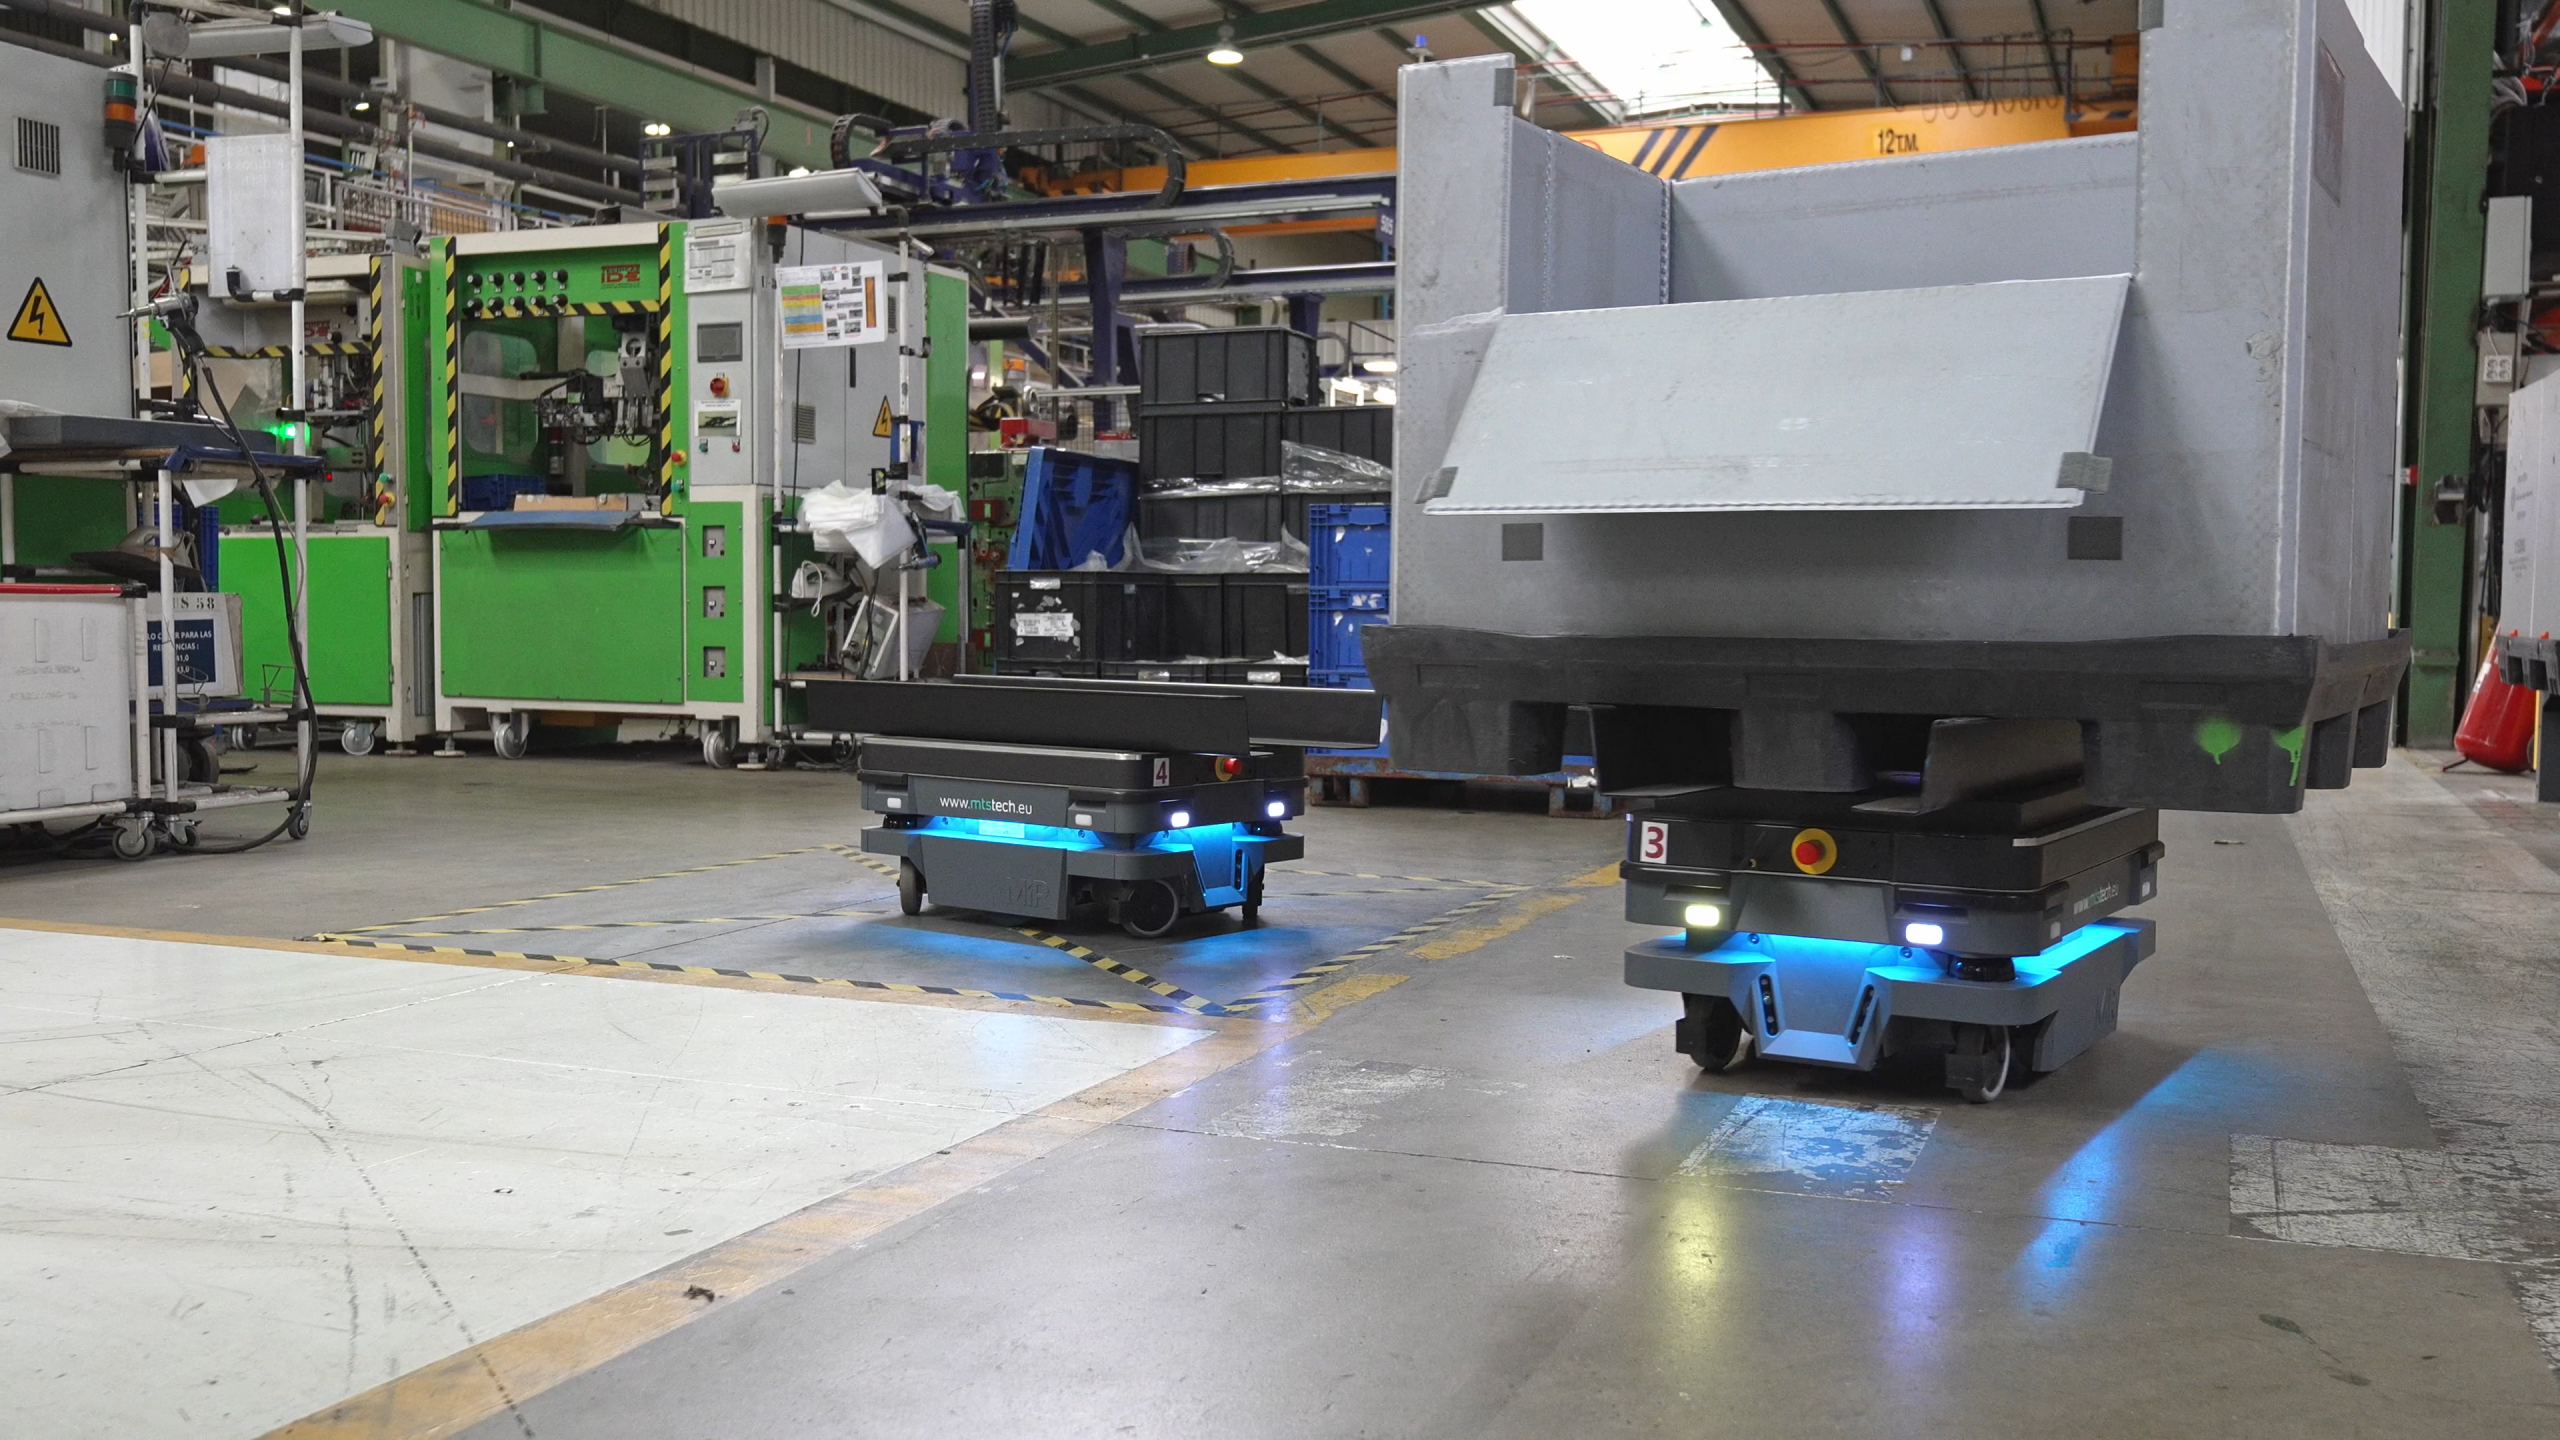
MiR: Engineering Next-Generation AMRs
Categories: Case Studies

